Time-of-Flight, or TOF, sensing measures distance by timing the interval between an emitted wave, typically infrared, and its reflection off a target. TOF image sensors extend this principle across an array of pixels, recording per-pixel distance to reconstruct the three-dimensional structure of a scene rather than a single point measurement. Validating this kind of sensor requires a bench that can move the target chart and the device under test through a controlled range of distances and positions, repeatably and without manual intervention, which is the specific problem this system is built to solve.
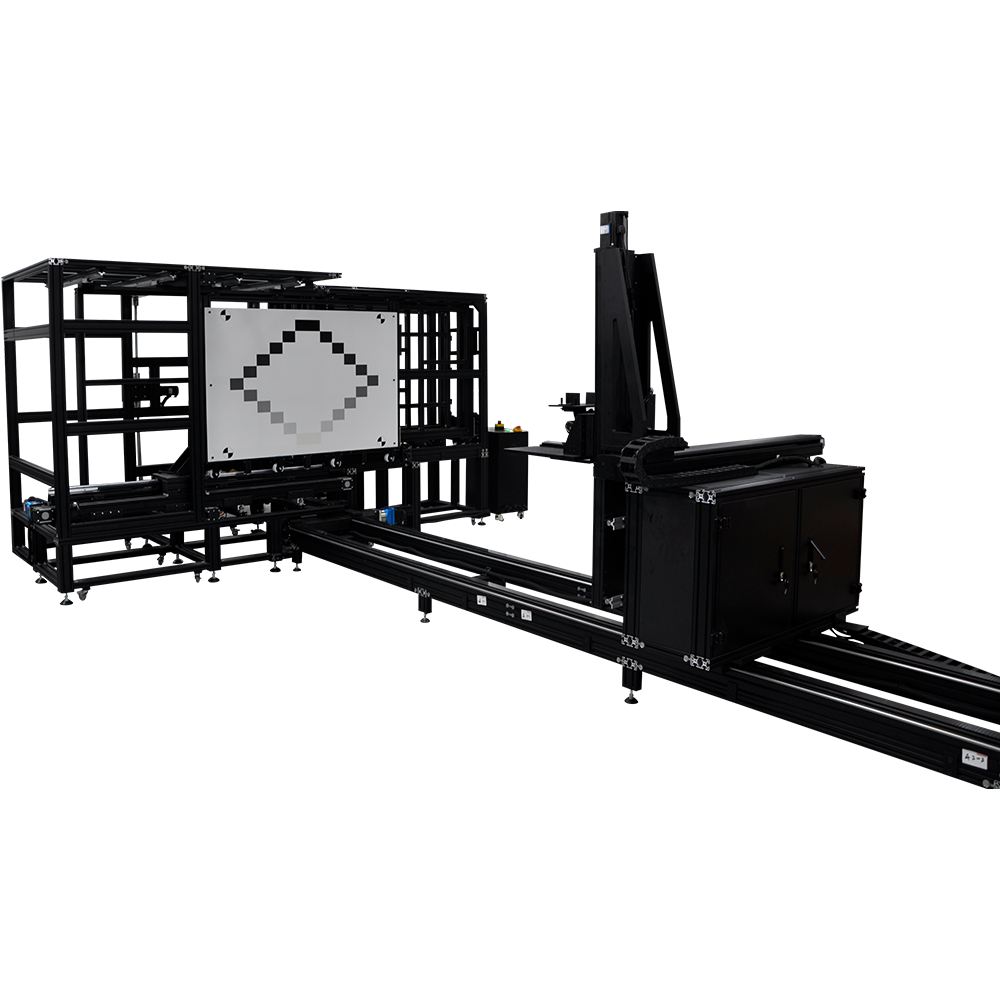
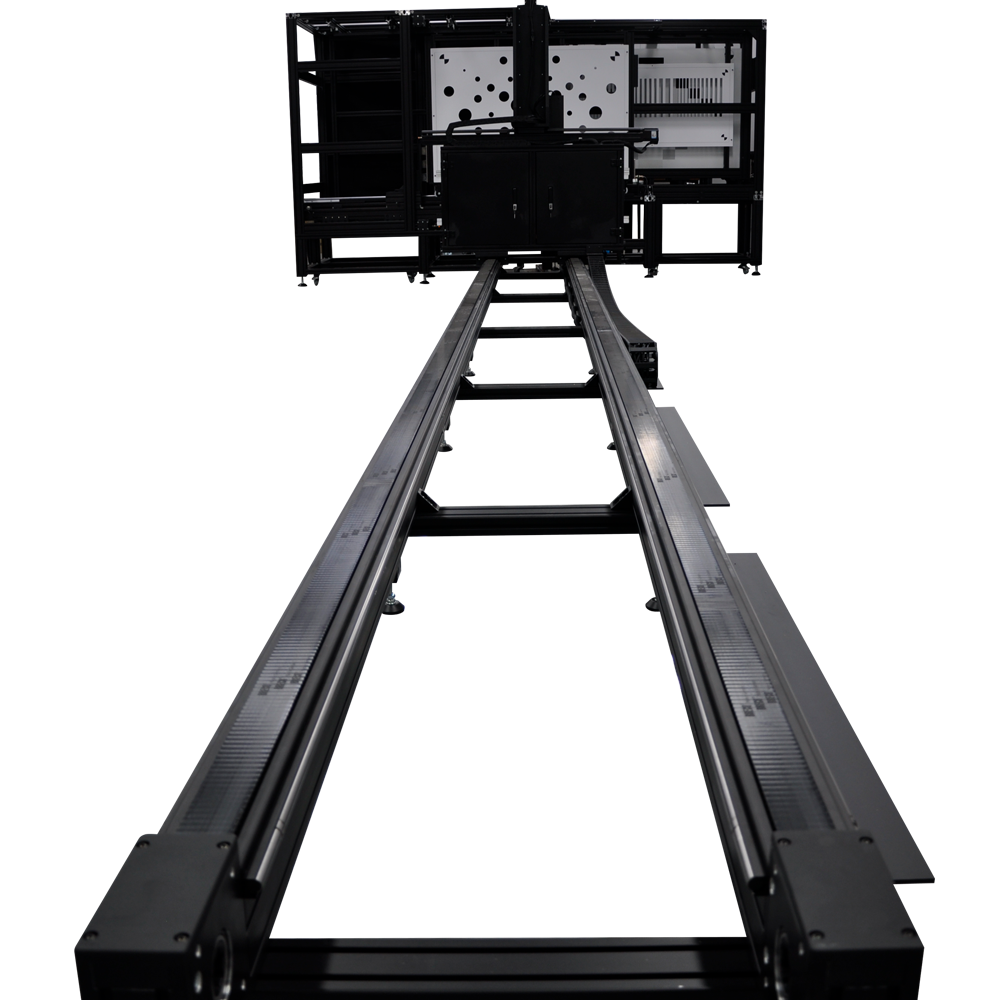
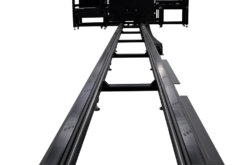
The TOF Automated Testing System pairs an Automatic Horizontal Chartmount System with an Automated Moving Rail, so chart switching and DUT positioning are both motorized rather than handled by an operator between each measurement. This removes the positioning variability that would otherwise contaminate distance and depth accuracy results, and it allows a full multi-distance test sequence to run unattended once configured.
The system supports several testing dimensions relevant to TOF sensor validation: automated distance measurement across the rail’s travel range, depth information detection to verify the sensor’s three-dimensional reconstruction accuracy, reflectivity inspection to characterize how the sensor responds to targets of differing surface reflectance, and multi-distance testing to build out a full accuracy or linearity curve across the measurable range rather than relying on single-point checks.
Mechanically, the system is built as a compact, stable structure, mounted on wheels with lockable feet, so it can be repositioned within a lab and then fixed in place for a stable, repeatable test session. This combination of automated chart and rail control with a stable mechanical base is intended to reduce both operator-introduced variability and the setup time required between test distances.
DSLR & Mirrorless
3D Camera
Drone & Action camera